Scene2Gym: Transforming Real-World Scenes into Interactive Training Environments for Robot Learning
Published in IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
Ziheng Ji, Fengyi Chen, Ziqian Wang, Zhitao Wang, Feng Qiu, Wenguo Hou, Ming Yang, Tong Qin
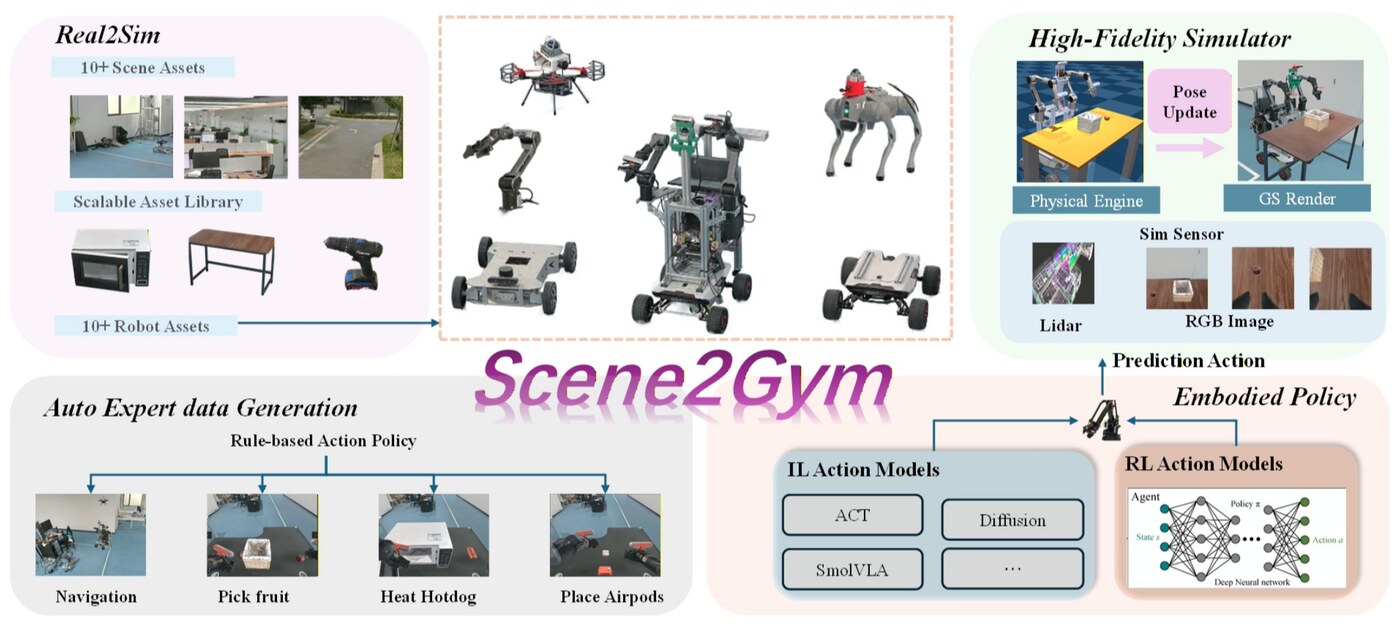
Scaling embodied intelligence remains bottlenecked by the high cost of manual asset engineering and persistent sim-to-real gaps. Scene2Gym is a framework that transforms real-world scene observations into interactive, metric-consistent digital twins for embodied policy learning. It combines 3D Gaussian Splatting (3DGS) with an object-centric metric alignment pipeline: 3DGS improves visual realism to reduce the visual gap, while metric alignment anchors reconstructed assets to real-world scale for geometrically consistent, contact-rich interaction. A hybrid co-simulation stack decouples photorealistic rendering from the physics clock, providing time-synchronized observations for closed-loop policy training.
Across tasks with increasing interaction complexity, Scene2Gym yields consistent sim-to-real gains. Imitation learning policies trained entirely on Scene2Gym-synthesized data achieve real-world success rates comparable to policies trained on costly human demonstrations; articulated-object manipulation transfers zero-shot to a real-world microwave-heating task; and visual reinforcement learning policies reach a 56% zero-shot real-world success rate, highlighting the importance of visual fidelity and perception-action consistency for transferable embodied learning.
Recommended citation: Z. Ji, F. Chen, Z. Wang, Z. Wang, F. Qiu, W. Hou, M. Yang and T. Qin, "Scene2Gym: Transforming Real-World Scenes into Interactive Training Environments for Robot Learning," IROS, 2026.